Primera edición

Bionic Hand (anthropomorphic)

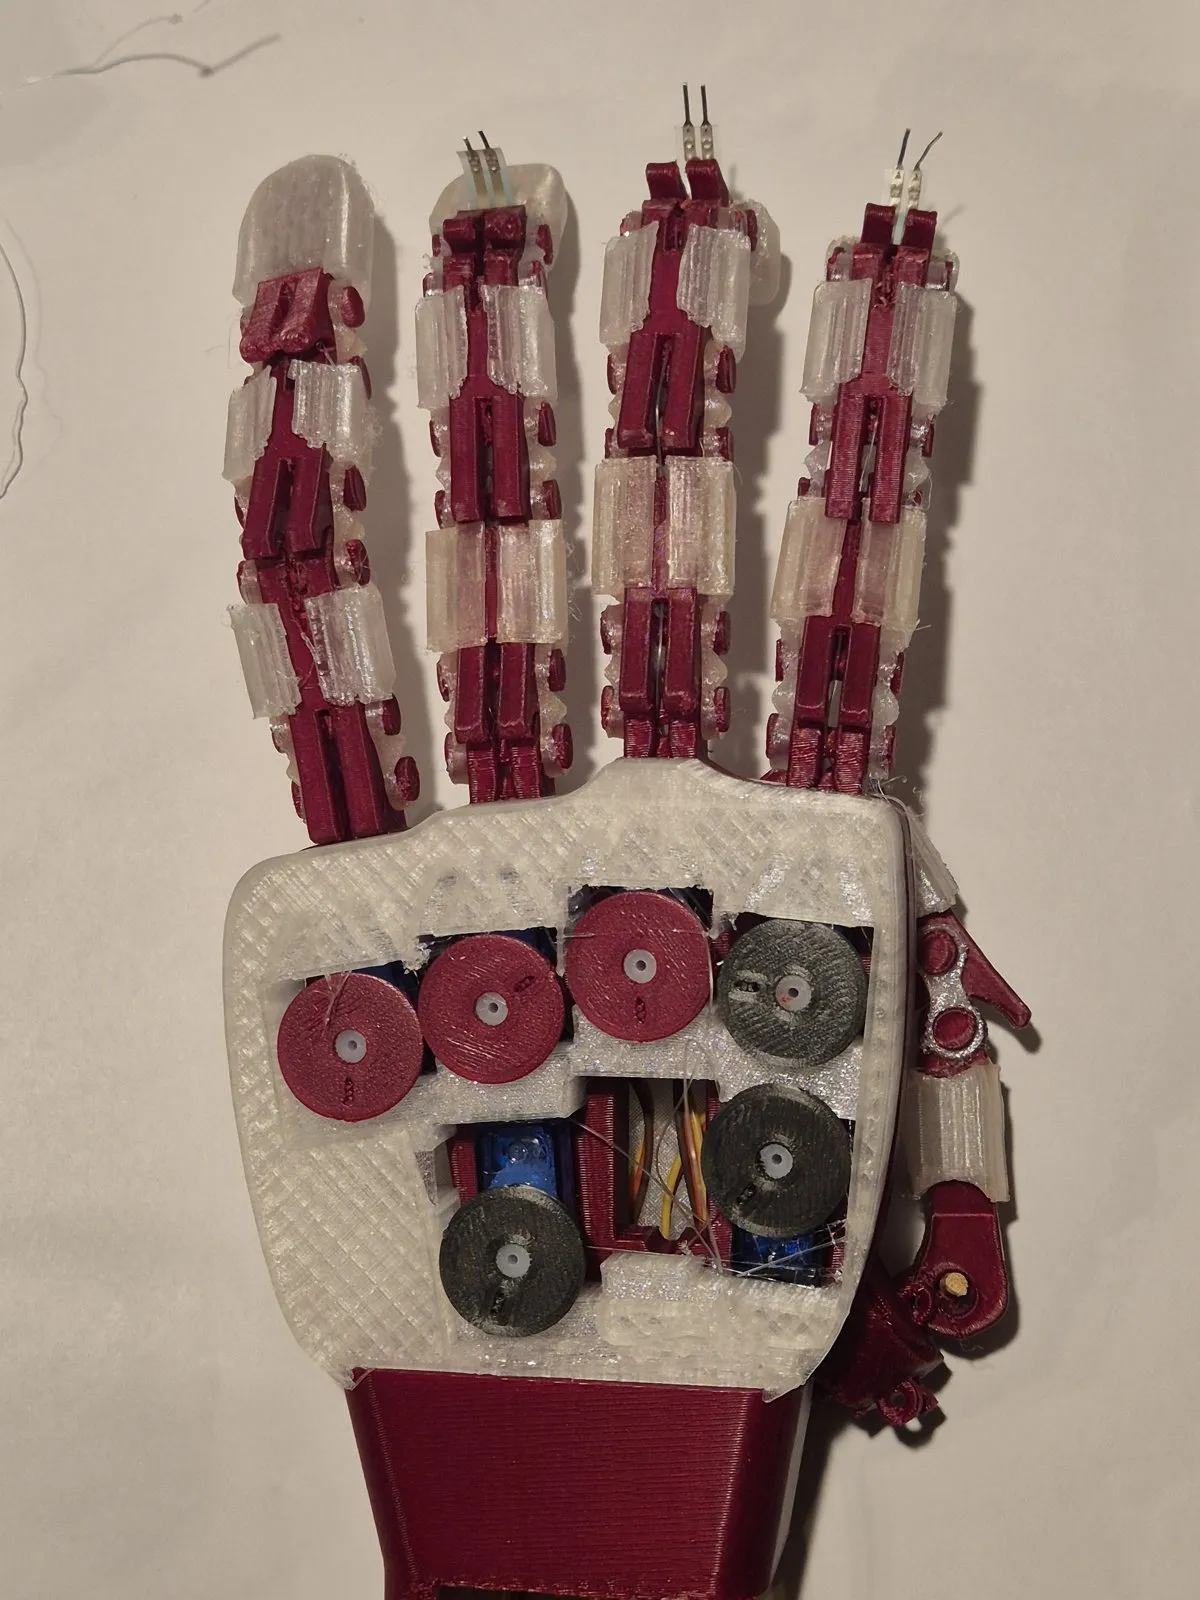
Human-proportioned fingers, a thumb that swings in front of the palm, and grip presets. An educational robotics project.

Dificultad
Advanced
Tiempo de montaje
4 to 5 evenings
Guía digital 24 €
Pedir por correo

Respondemos en un día con los datos de pago (transferencia o PayPal) y te enviamos los archivos por correo justo después del pago.

Recibes el PDF, el código y los archivos 3D por email. Precio con todos los impuestos.

Kit con piezas 94,46 €

El kit incluye la guía. Avísame cuando el kit esté listo.

Esta página aún no está traducida, por eso se muestra en inglés.

Qué recibes

  • PDF guide: finger proportions, thumb opposition, tendon routing, grip planning
  • MicroPython firmware with eight grips and safe thumb sequencing, plus unit tests for the maths that you can run on a computer
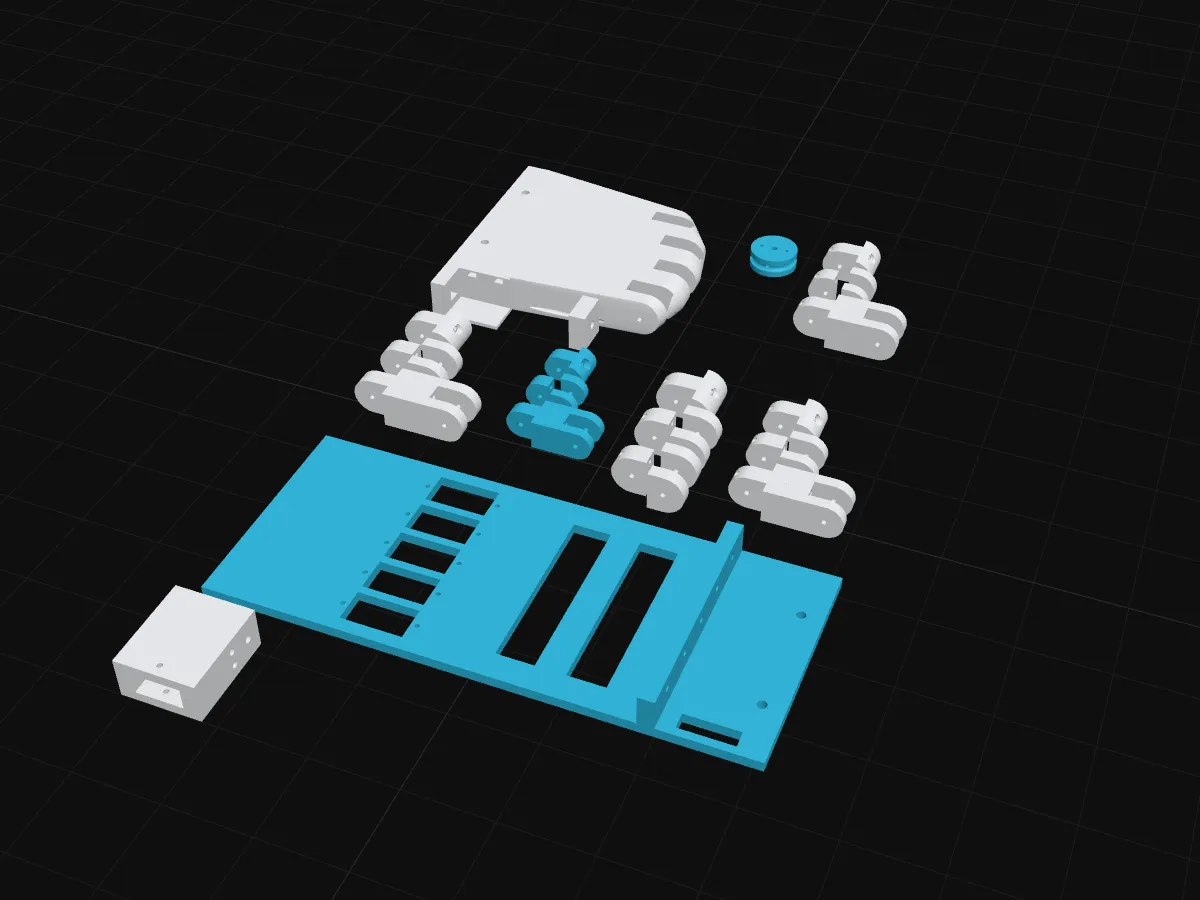
  • Printable parts (OpenSCAD source + STL)

Para quién es

Builders who finished the simple hand or have good 3D printing experience. Not a prosthesis or a medical device.

The thumb is what makes a hand useful. This hand has a sixth servo inside the palm that swings the thumb in front of the fingers, so it can pinch and hold a pen.

Piezas que necesitas

  • 1× ESP32 DevKit, 38-pin, ESP-WROOM-32, CP2102, USB-C
  • 6× MG90S metal-gear micro servo, 180°
  • 1× Power adapter 5 V 4 A, 5.5×2.1 mm barrel plug
  • 1× DC barrel jack 5.5×2.1 mm female to screw terminal adapter
  • 1× Electrolytic capacitor 1000 µF (16 V or higher)
  • 2× Solderless breadboard, 400 points (half size)
  • 24× Dupont jumper wires male–male 20 cm (pack of 40)
  • 4× Braided fishing line ~0.3–0.4 mm, ≥15 kg (per metre)
  • 3× Round elastic cord 1 mm (per metre)
  • 12× M3 screw, 8–20 mm, with nut (from an assortment box)
  • 14× M2 × 5 mm self-tapping screw
  • 1× USB-C data cable 1 m (USB-A to C)
  • 1× Index finger (3 phalanges) 3D
  • 1× Middle finger (3 phalanges) 3D
  • 1× Ring finger (3 phalanges) 3D
  • 1× Little finger (3 phalanges) 3D
  • 1× Thumb (metacarpal + 2 phalanges) 3D
  • 1× Palm 3D
  • 1× Thumb rotation base 3D
  • 1× Forearm (servo bed) 3D
  • 6× Tendon spool 3D

No incluido en el kit

  • Nothing else needed besides a computer

La lista completa con tiendas y alternativas más baratas está en la guía.

Echa un vistazo

El primer capítulo de la guía, gratis.

A hand shaped like a hand

What “anthropomorphic” means here

The simple hand has five identical fingers in a row. This one copies the layout of a human hand:

  • every finger has its own length and width, roughly in human proportions,
  • the knuckle line is stepped: the middle finger reaches furthest, the little finger is shortest and sits further back,
  • the thumb has three bones and, most importantly, a second motion: opposition.

The principle of moving the fingers is the same as in the simple hand: a braided-line tendon on the palm side of each finger, wound by a servo spool in the forearm, and elastic cord on the back pulling the finger straight again.

The thumb: why opposition matters

Try picking up a coin with your thumb held flat beside your hand. You cannot. To pinch, your thumb must swing in front of the palm so its tip can meet a fingertip. That swing is called opposition, and it is what makes human hands so good at holding things.

This hand has six servos: five curl the fingers and the thumb, and the sixth sits inside the palm and rotates the thumb’s base to swing it in front of the palm.

Grips, not just gestures

Researchers sort the ways we hold things into a handful of basic grips. The firmware has the most useful ones, each a set of six values from 0 to 1:

GripUseThumb
powera bottle, a handle: all fingers around the objectpartly in front
pincha coin, a pen tip: thumb meets indexfully in front
tripoda pencil: thumb, index and middlefully in front
laterala key, a card: thumb presses on the side of the indexbeside the palm
hooka bag handle: fingers curled, thumb out of the waybeside the palm
point, peace, opengestures

Planning the thumb’s path

If the thumb curls and swings at the same time, the curled thumb can crash into the index finger on its way across the palm. So when a grip change moves the opposition a lot, the firmware does it in three steps:

  1. straighten the thumb (the fingers stay where they are),
  2. swing the thumb to its new position,
  3. move everything to the final grip.

Small opposition changes (less than 0.2) go directly.

What is in this guide

  1. A hand shaped like a hand (this chapter, free)
  2. Parts and printing (the hardest print in the series)
  3. Assembly: fingers, the thumb base, tendons, wiring
  4. The code: grips, transitions, calibration
  5. Troubleshooting and what next

If you have not built a tendon-driven hand before, the simple hand’s guide explains the tendon maths and the basic assembly in more detail.

Preguntas

Can this be used as a prosthetic hand?

No. It is an educational robotics project, not designed, tested or certified for use on a person.

Is this tested?

No. This is a first edition and the most advanced design in the line: the parts are designed and checked in CAD, not yet printed and assembled. Expect to adjust print clearances for your printer.

Guía digital 24 €
Pedir por correo

Respondemos en un día con los datos de pago (transferencia o PayPal) y te enviamos los archivos por correo justo después del pago.

Recibes el PDF, el código y los archivos 3D por email. Precio con todos los impuestos.

Combina con